Shared, persistent site record for people and robots

Site capture joined to your ledgers and drawings: what is where and what has changed, kept in one record. Site teams read it today, and robots next.

YODO LABS Inc.Formerly PixelX Inc.

The word YODO spelled in a mosaic of thousands of frames captured at our sites

Thousands of frames captured at our sites

Featured inWIREDNikkei
Backed byAbelia CapitalIncubate Fund
Recognized byInstitute of Science TokyoOIST InnovationMIT Association of Japan Venture ForumNEDOStartup Initial Program OSAKA (SIO)
Product
YODO Asset World

Film the unit in front of you. Its record opens.

From the image alone, YODO Asset World works out where you are standing and which unit is in frame, even among identical machines. Its record opens on the spot, with no tag on the asset and nothing to scan.

  1. 01

    Point the camera

  2. 02

    Locate

  3. 03

    Read

Customers

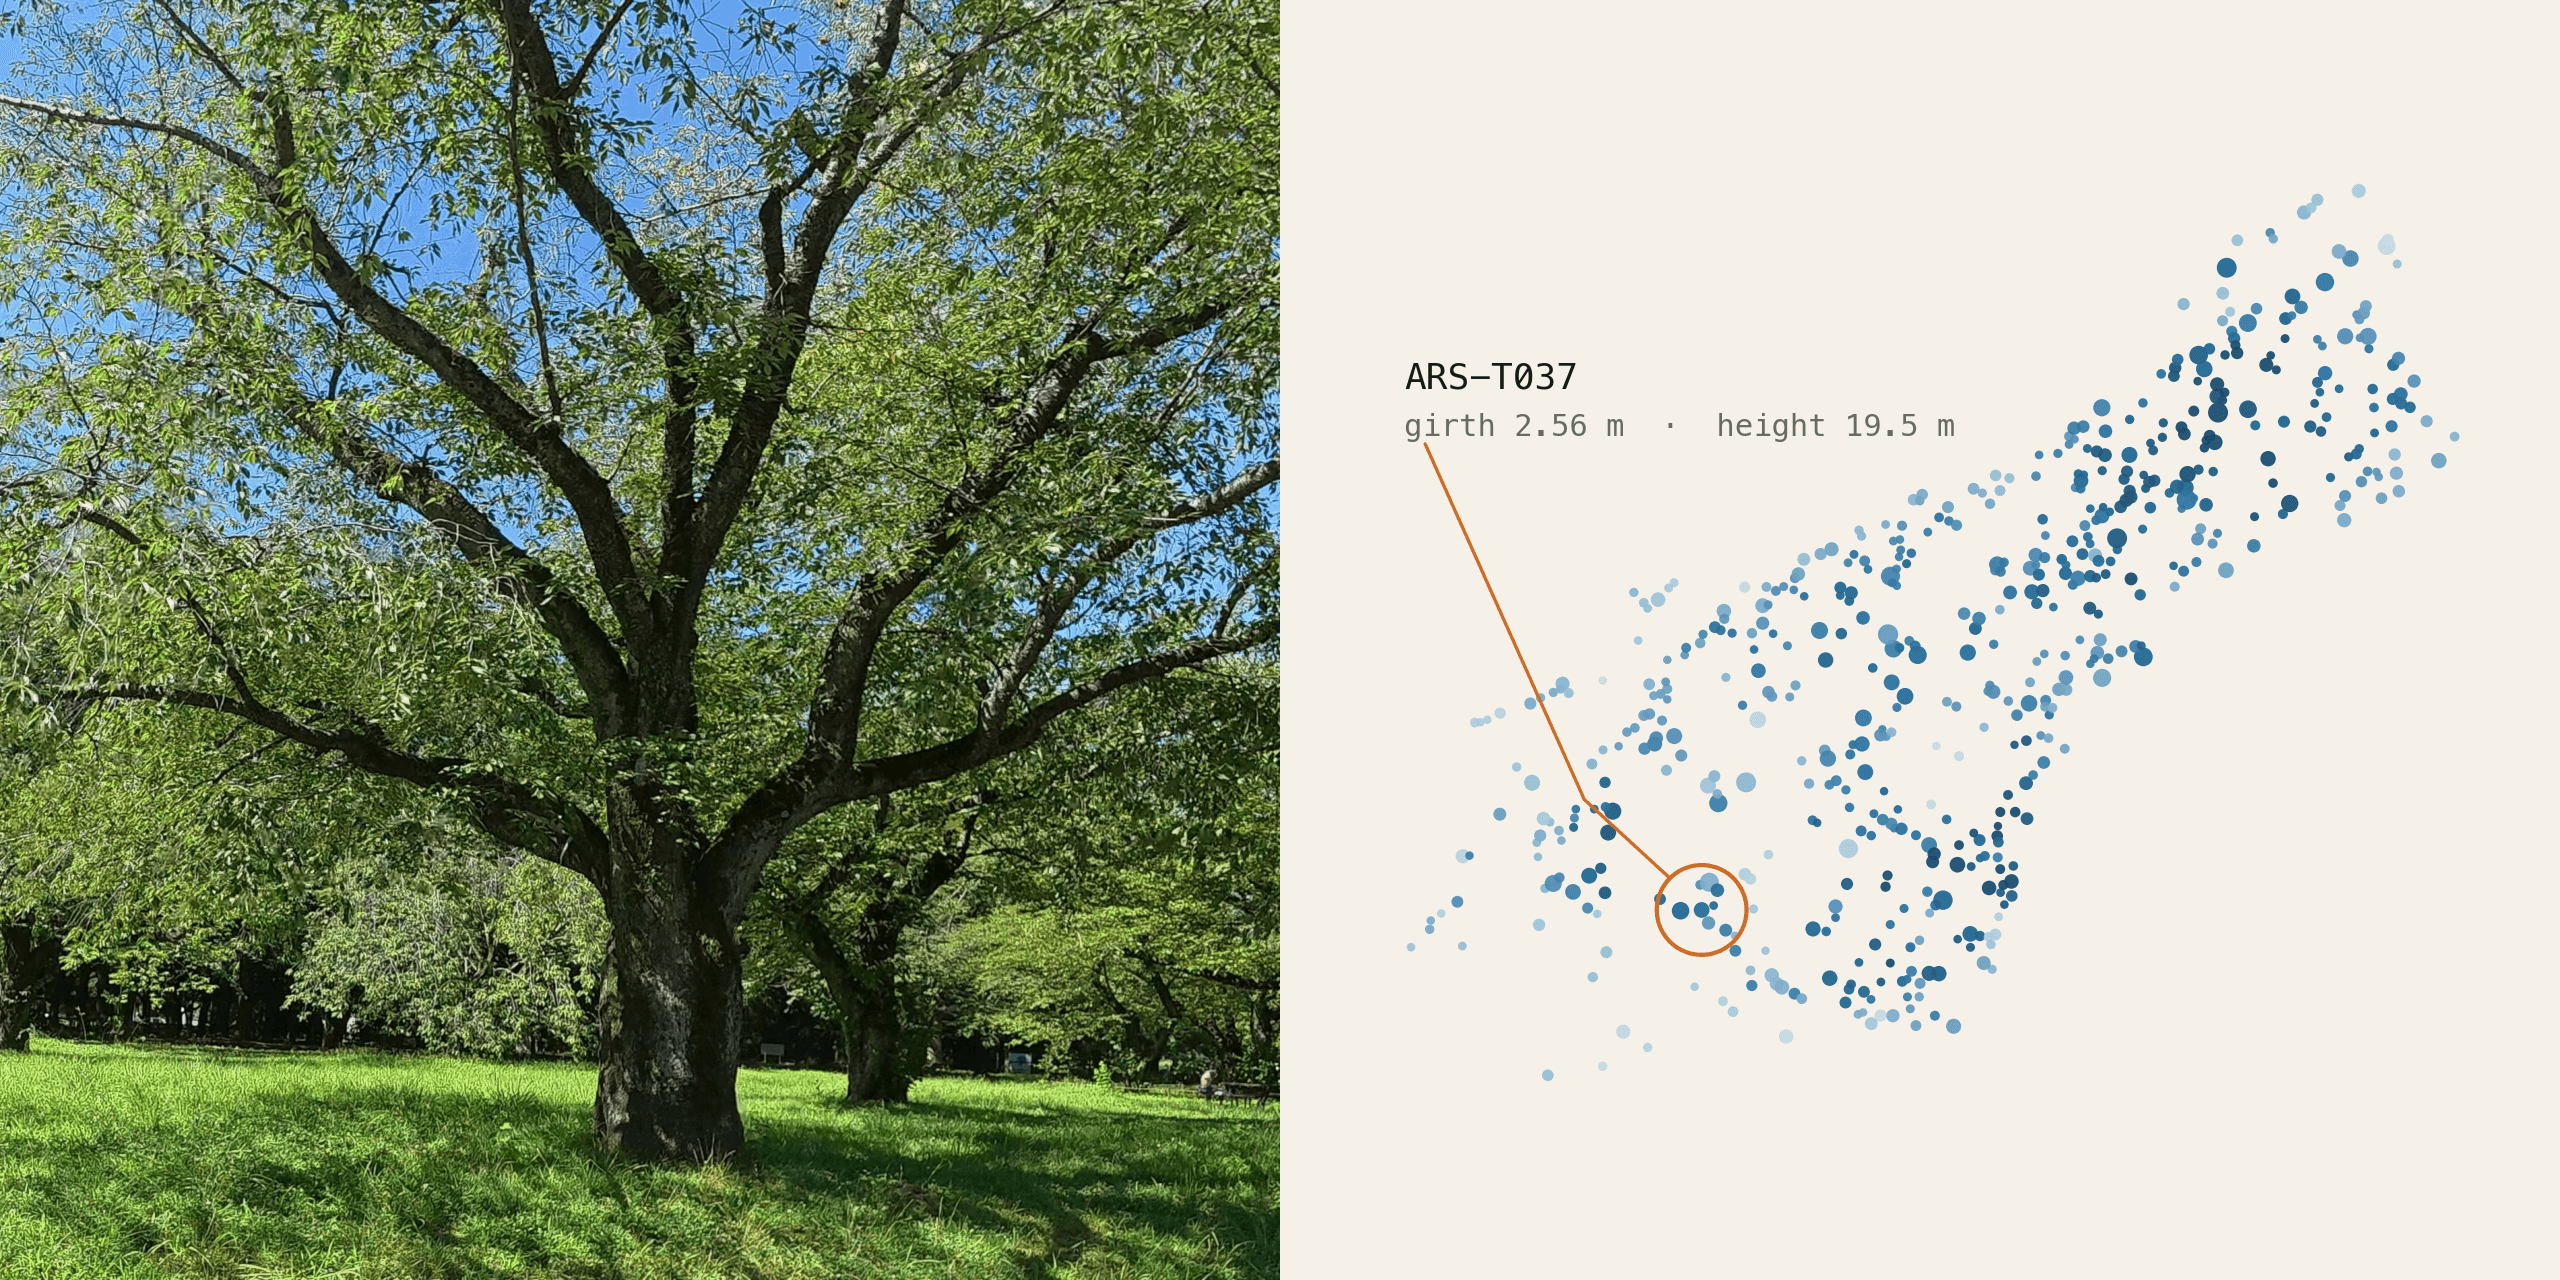
Machines, trees, bicycles: each one in frame is tied to its own row in the ledger.

From mines to city streets, we have worked alongside six kinds of site. At the airport and in the factory, robots have started to use the record too.

RICOH
Machine rooms and plants

From 360° video, each machine is matched to its row in the equipment register.

Ricoh Company, Ltd. (technology partnership)

サキュレ
Roads and streets

From patrol video, everything on the street goes into the register, one by one.

Sakyure Co., Ltd.

Mining

Equipment identified from video, so decisions at the mine are faster and surer.

Australian Mine

NEDOMETI
Airport

A baggage-handling robot recognises each bag and what surrounds it.

New Energy and Industrial Technology Development Organization (NEDO) · Ministry of Economy, Trade and Industry (METI)

Factory

Robots from three companies work from the same record.

Three robotics companies

Technology

On-site spatial intelligence

A site-centric 4D model, shared by people and robots.

One site state

Field teams, office records and robots from three vendors read and write one model of the site. A robot continues where a person left off.

Site teamsWeb app · phone · tabletOfficeLedgers · drawingsRobotCompany ARobotCompany BRobotCompany C3D twin · asset IDs · historyRead · Write

Robot‑centric and site‑centric

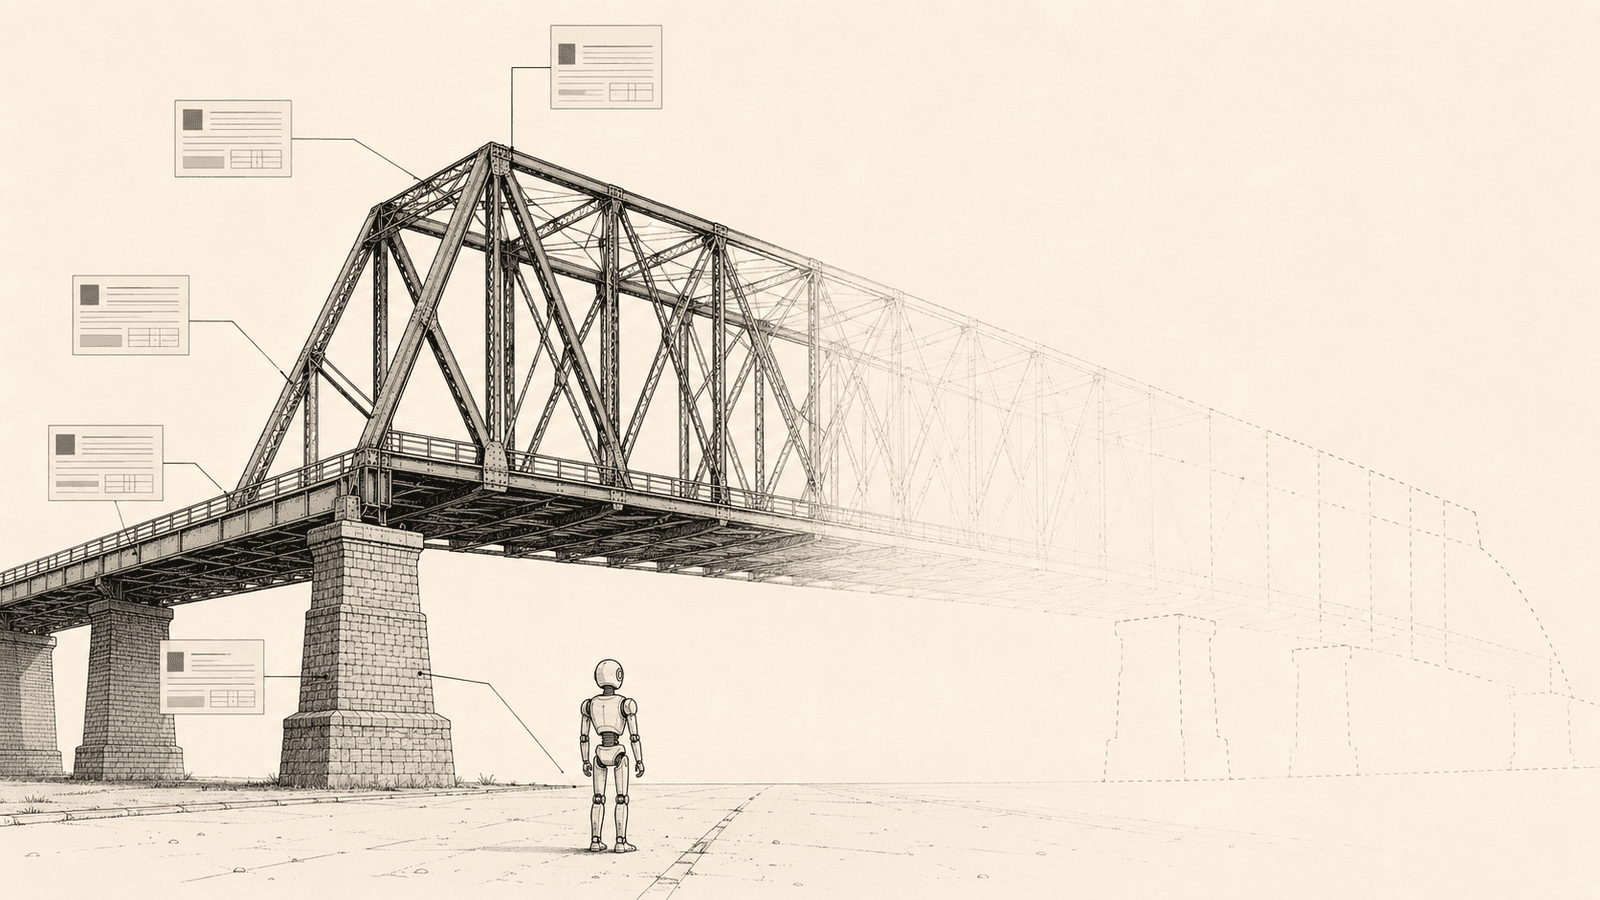
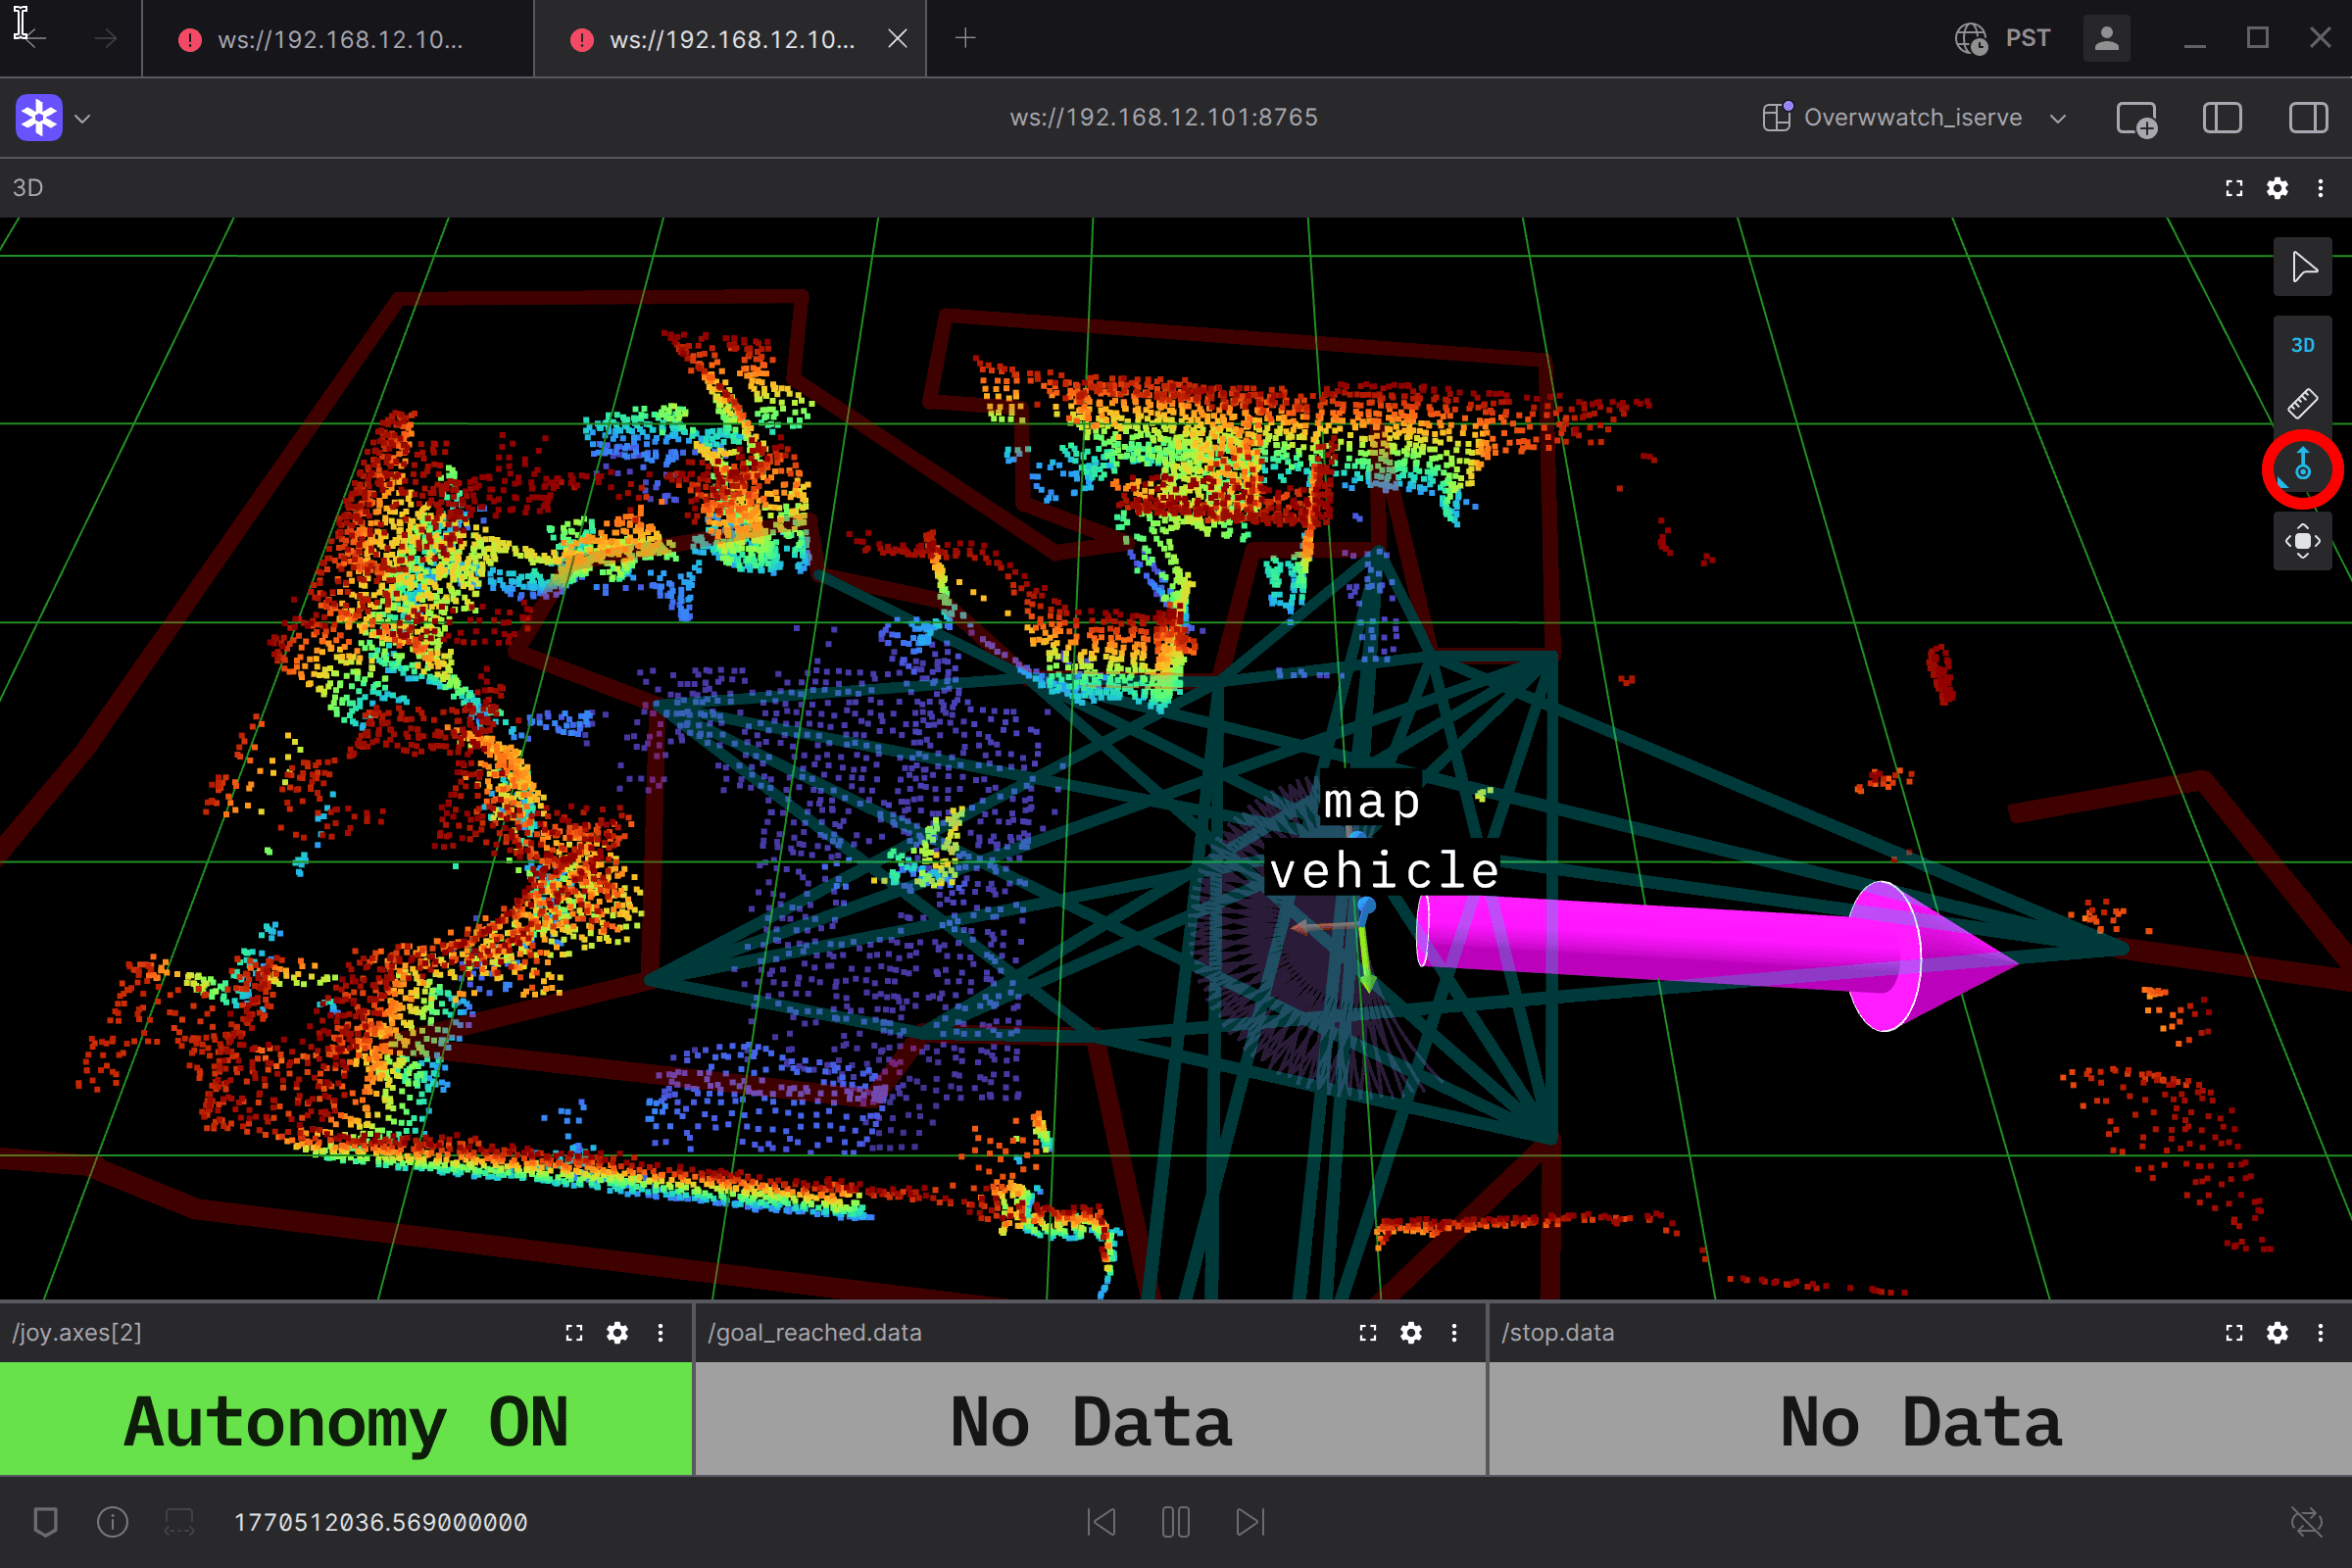
Alone, a robot has its own map, but only as unnamed geometry: it relabels objects each time they reappear, and a new pallet is just something not in its map. Connected, it sees persistent asset IDs, what changed beyond its sensors, and the other agents on site.

Robot-centric
Site-centric · YODO Asset World

From a robot's camera

Through the API, a robot sends one frame and receives its pose, the asset ID in view and that asset's record. Two identical tanks are resolved by position.

Foundations

PMP-014TNK-021CNV-007BLW-003VLV-1125 mOne walkcaptureminutes, any cameramodeldense 3D, to scaleunitsmetres, not pixelsassetseach pinned to its IDno survey kit, no targets

01

A metric model from one walk

One walk with a camera becomes a metric 3D model of the site, with no survey kit and no targets.

Each asset is pinned to its ID by position, and later frames from a phone or robot find their place in it. Every site we capture makes the next model better.

Team

Xiuxi Pan, PhD

Xiuxi Pan, PhD

Cofounder & CTO

Published work in Computer Vision, Computational Imaging, Generative Model. Led the production and implementation of AI solutions for major Japanese and international enterprises. Profiled by WIRED and Nikkei as an early pioneer of AI in Japan.

Sho Osawa

Sho Osawa

Cofounder & CEO

Former strategy consultant at Strategy& (PwC) and Westpac Banking Group. Scaled a SEA start-up insurer from zero to 150M in insured exposure in two years, leveraging automation and AI.

Bona Bai, PhD

Bona Bai, PhD

Robotics Lead

15 years building autonomous systems across Amazon (Astro), Google Wing, and Figure AI. Full-stack autonomy from sensor fusion and perception through to real-time decision making.

Prof. Tomoya Nakamura

Prof. Tomoya Nakamura

Research Advisor

Professor at The University of Osaka and Visiting Professor at Stanford University. Computational Imaging, Computer Vision, AI Optics.

Running a site

Start with one inspection video. See what YODO Asset World finds.

Building robots

Give your robot what the rest of the site has already seen.

Joining the team

We are hiring research scientists, solutions engineering managers, product managers and interns. If no listed role fits, write to us anyway.